Skip to content
Langhui

PRODUCTS · CAPTURE HARDWARE

Select data capture hardware by task requirements

Filter head-worn devices, gloves, teleop robot bases and capture equipment by form factor. Review specifications, recording samples and integration requirements; development targets require separate validation.

12 matching devices
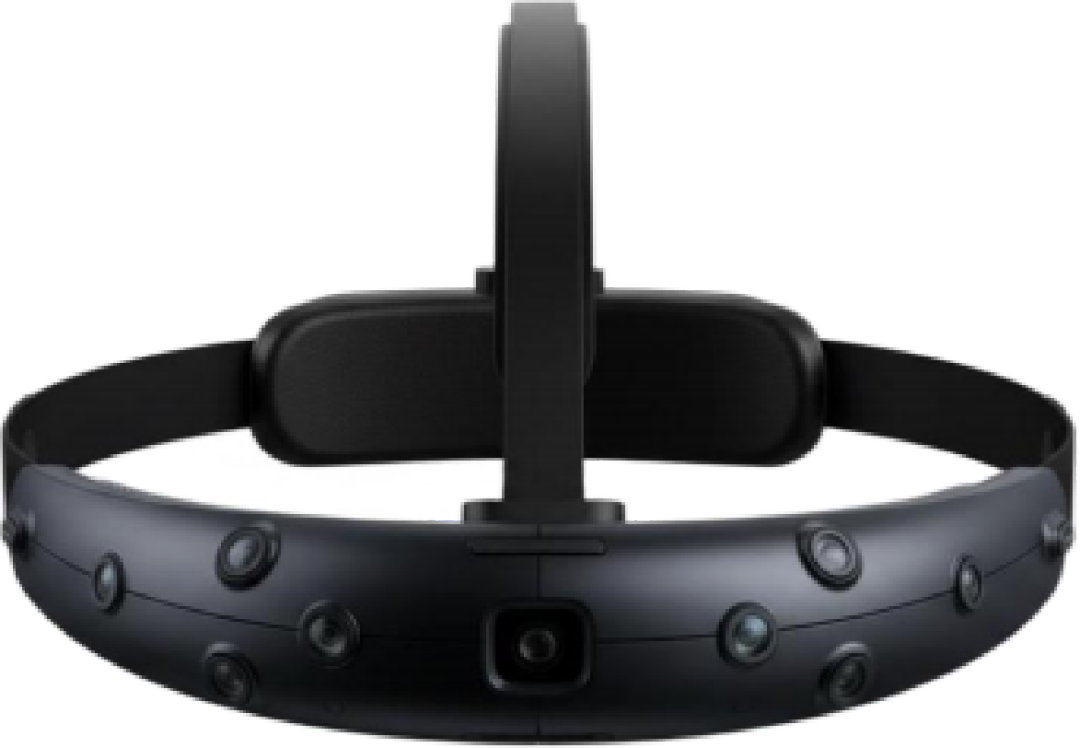
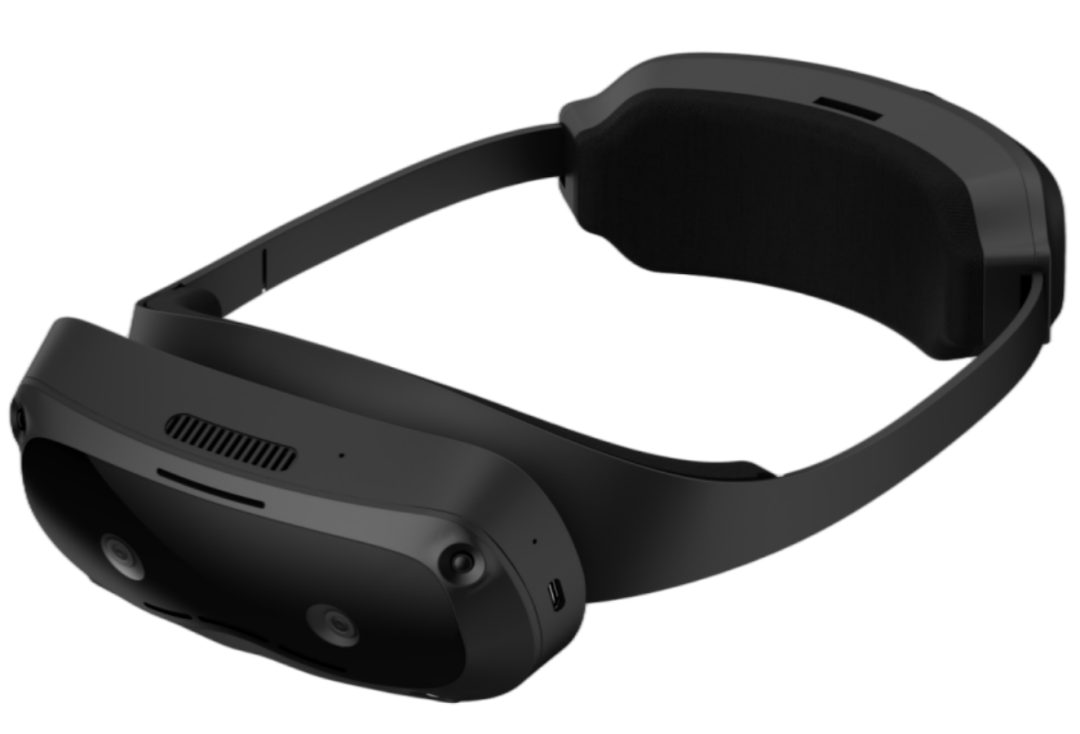
In productionE6 · Six-Camera Ego Capture Device

E6 · Six-Camera Ego Capture Device

4 global-shutter grayscale cameras plus 2 RGB cameras with on-device SLAM output. Choose between the two RGB sensor versions when ordering.

6 cameras4 grayscale + 2 RGB
370grear-battery balance
<1μscamera hardware sync
~2kHzIMU + 6DoF output
On-device trajectoryGlobal shutterPeripheral sync
View details →
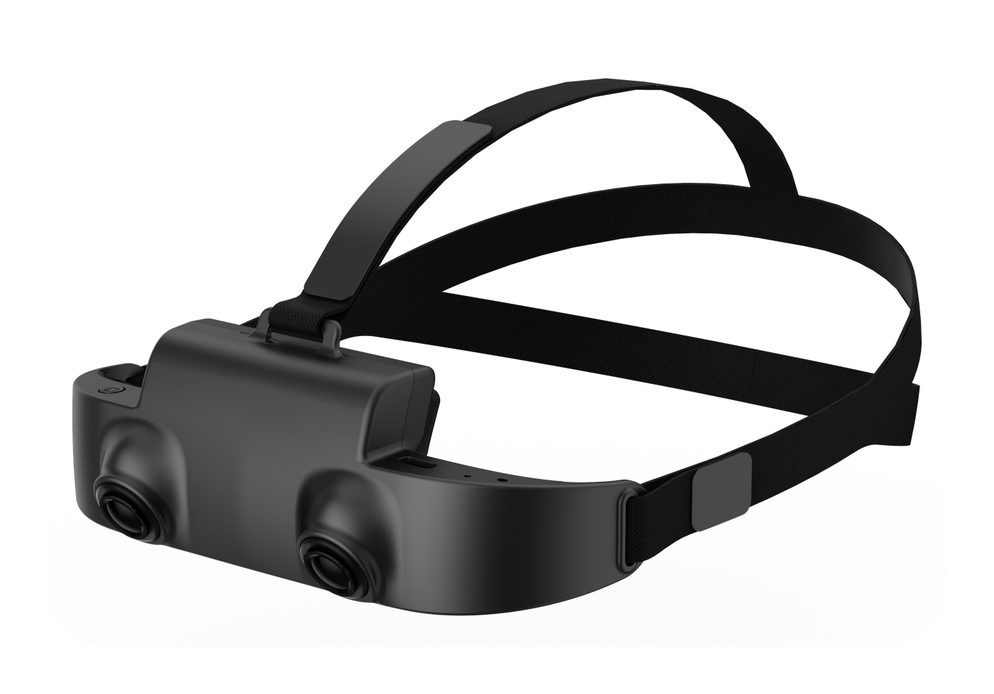
In productionE2 · Lightweight Binocular Ego Headband

E2 · Lightweight Binocular Ego Headband

Two RGB global cameras (1600×1200, up to 30 FPS), per-camera HFOV 139° / VFOV 111°, IMU and magnetometer at 1000 Hz, binocular hardware sync under 1 µs. E2 has no on-device SLAM; pose is reconstructed offline on a computer.

2× RGB1600×1200 up to 30 FPS
H139° / V111°per-camera FOV
1000 HzIMU + magnetometer
<140g / 6hweight / 2000 mAh
Global shutterPeripheral sync
View details →
Development stage / supply to confirmE8 · Multimodal Ego Capture Platform

E8 · Multimodal Ego Capture Platform

The matrix lists ten cameras plus TOF and mocap expansion; the former detail page lists a different configuration. Tracking figures are development targets; confirm camera configuration, current supply and motion-capture options.

10 + TOFconfiguration to confirm
280g120g main unit
48 TOPSXR2 Gen2 NPU
1.5mmSLAM target
On-device trajectoryGlobal shutterDepth dataPeripheral syncFull-body mocap
View details →
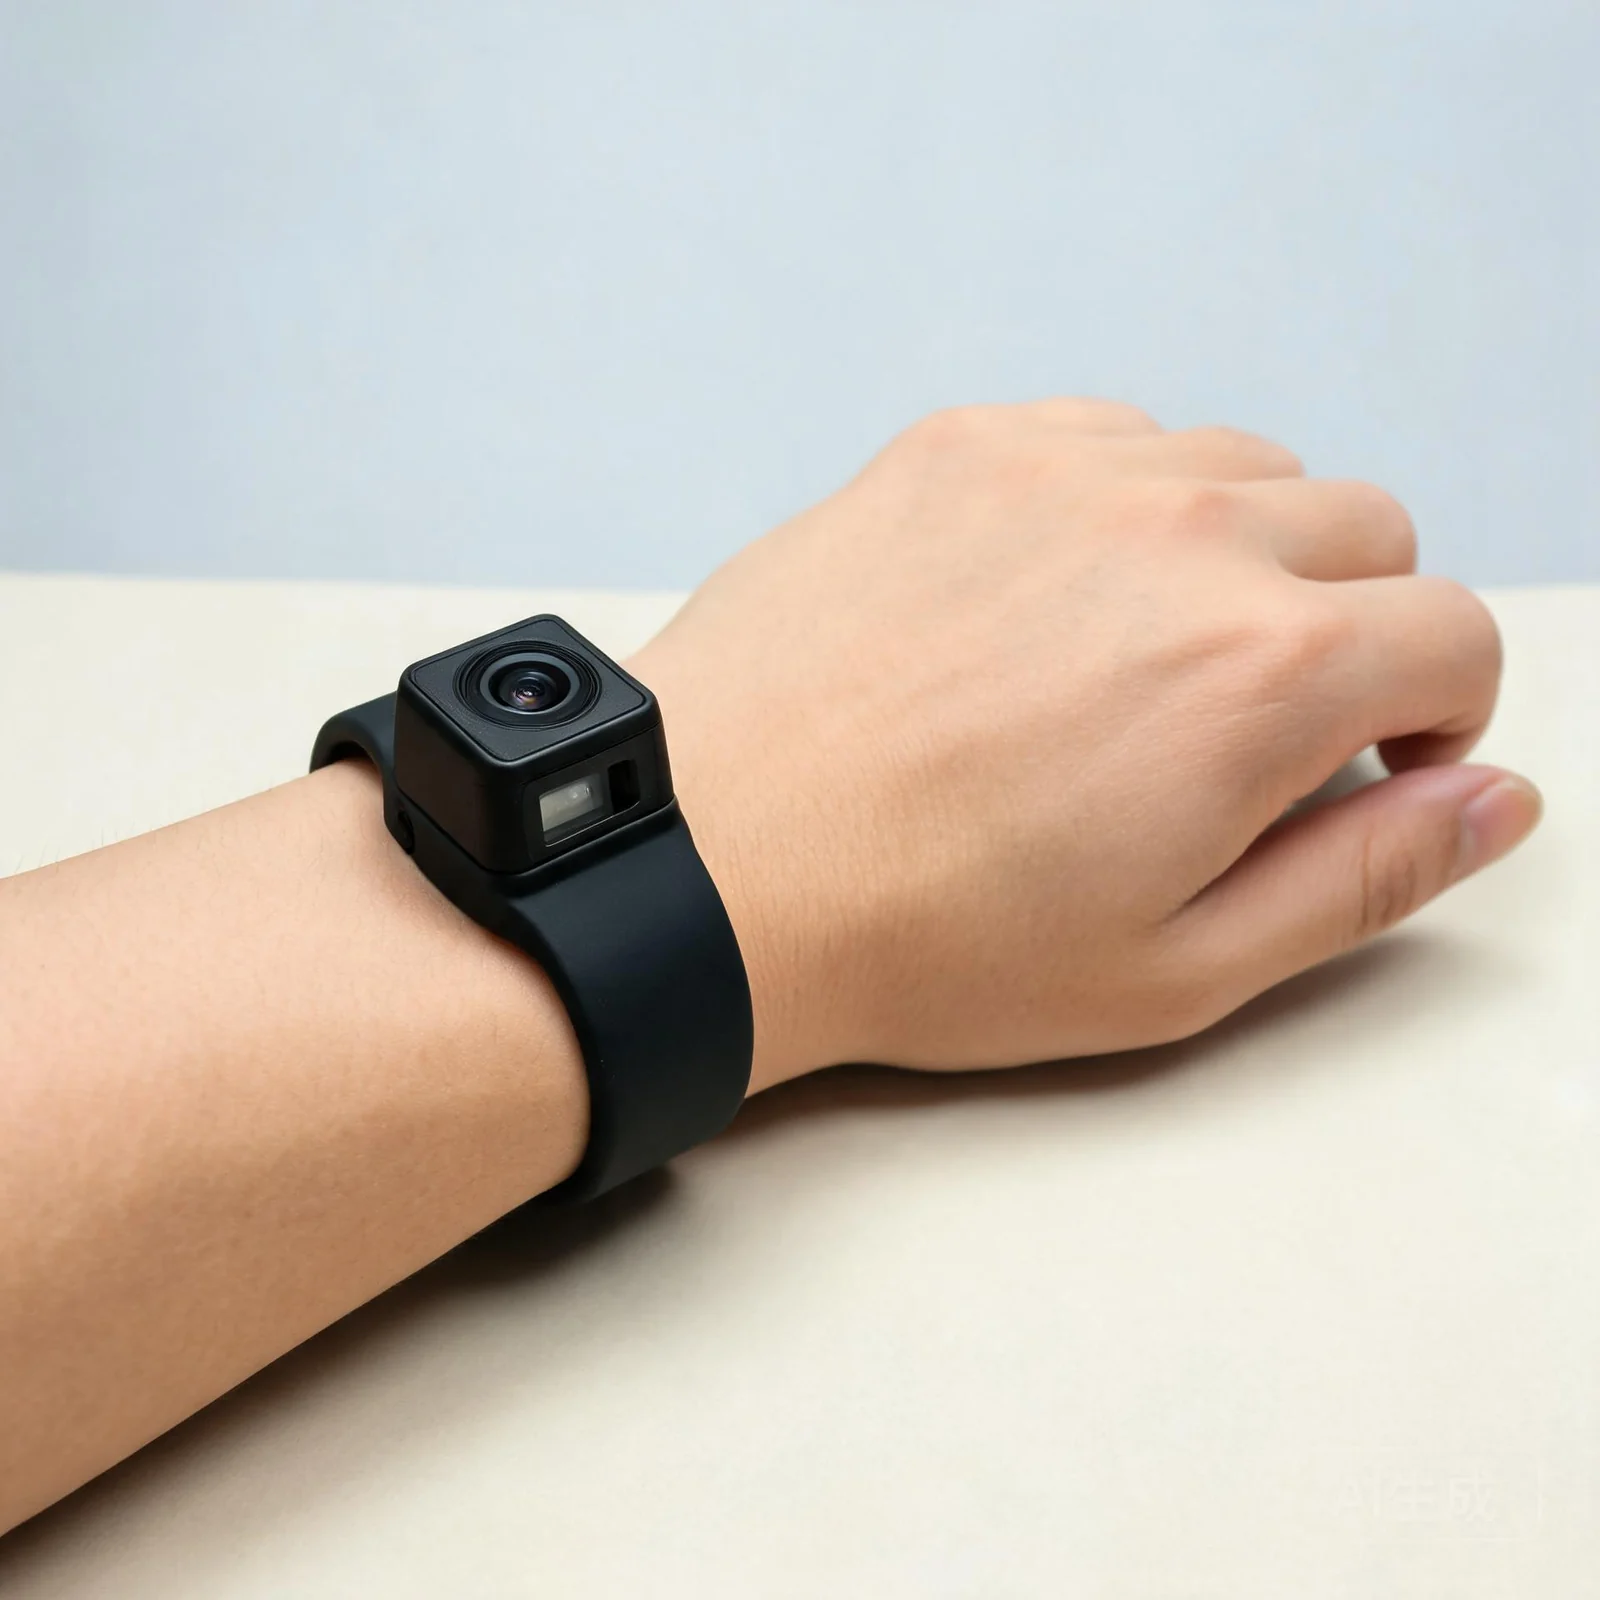
Development stage / supply to confirmWrist Camera

Wrist Camera

Adds a close-up first-person view for fine hand operations and synchronizes to E6/E2 using PPS + UART.

1280×102430 / 60fps
100gwrist-worn
200°diagonal FOV
<1mshost sync
Peripheral sync
View details →
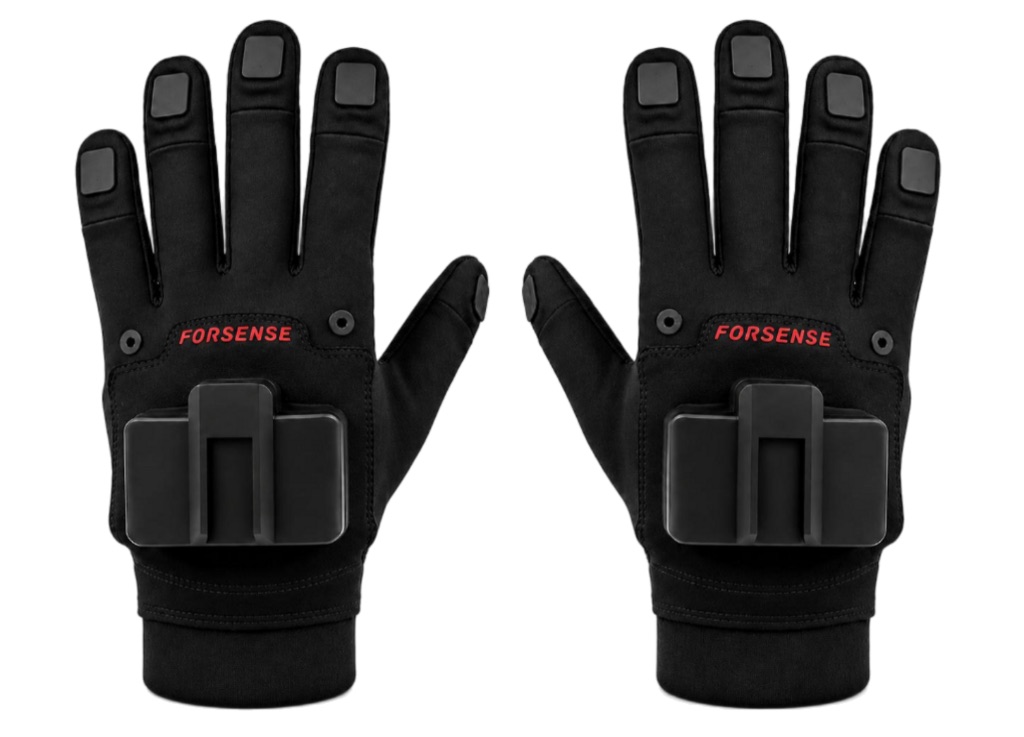
In productionG7 · Magneto-Inertial Hand Mocap Glove

G7 · Magneto-Inertial Hand Mocap Glove

Forsense production · TOBI integration. Choose G7 for fingertip spatial pose: 5× EMF+IMU, 120 Hz, <20 ms wired / <30 ms wireless, 2 mm / 3° (datasheet). Prefer G2-L in metal-heavy or close bimanual scenes.

120 Hzsensor rate
<20 / <30 mswired / wireless E2E
2 mm / 3°position / orientation
115 g±5 gper glove
Hand mocapPeripheral sync
View details →
In productionG2-L · Wireless Inertial Hand Mocap Glove

G2-L · Wireless Inertial Hand Mocap Glove

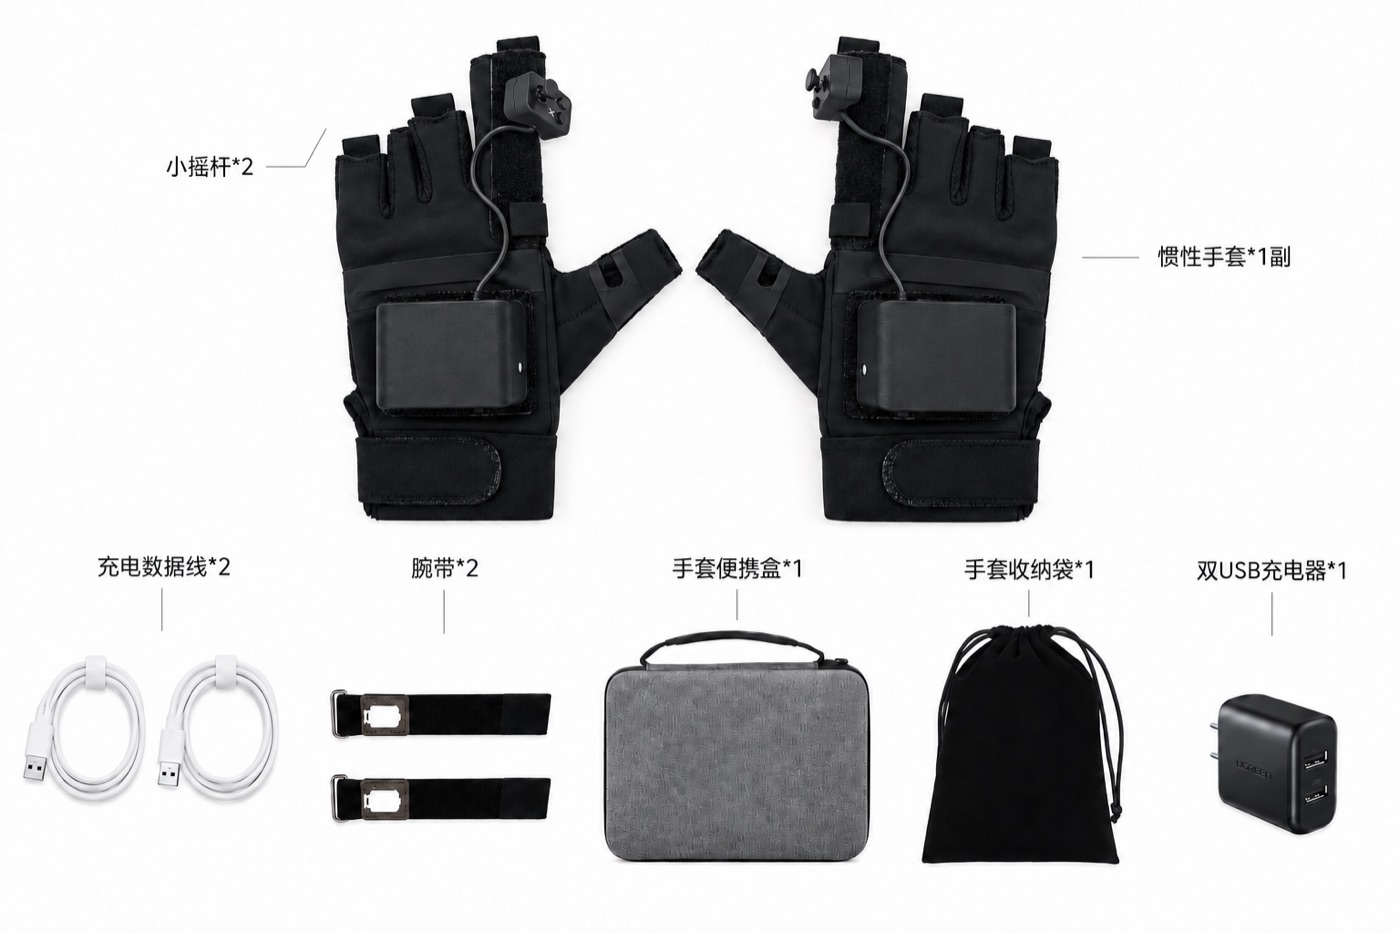
In the product illustration

  • Mini joysticks ×2
  • Inertial gloves ×1 pair
  • Charging/data cables ×2
  • Wrist straps ×2
  • Glove carrying case ×1
  • Glove storage bag ×1
  • Dual-USB charger ×1

Illustration only. Final delivery is subject to the written specification.

Forsense production · TOBI integration. Wireless long-session gesture capture: 1+8+wrist IMU, ≤20 ms, 50 Hz, BT 5.1, 7 h (datasheet). Need millimeter-level fingertip position tracking? See G7.

1+8+wristIMU layout
≤20 mssignal latency
50 Hzoutput rate
7 h / 90 g±5 gbattery / weight
Hand mocapPeripheral sync
View details →
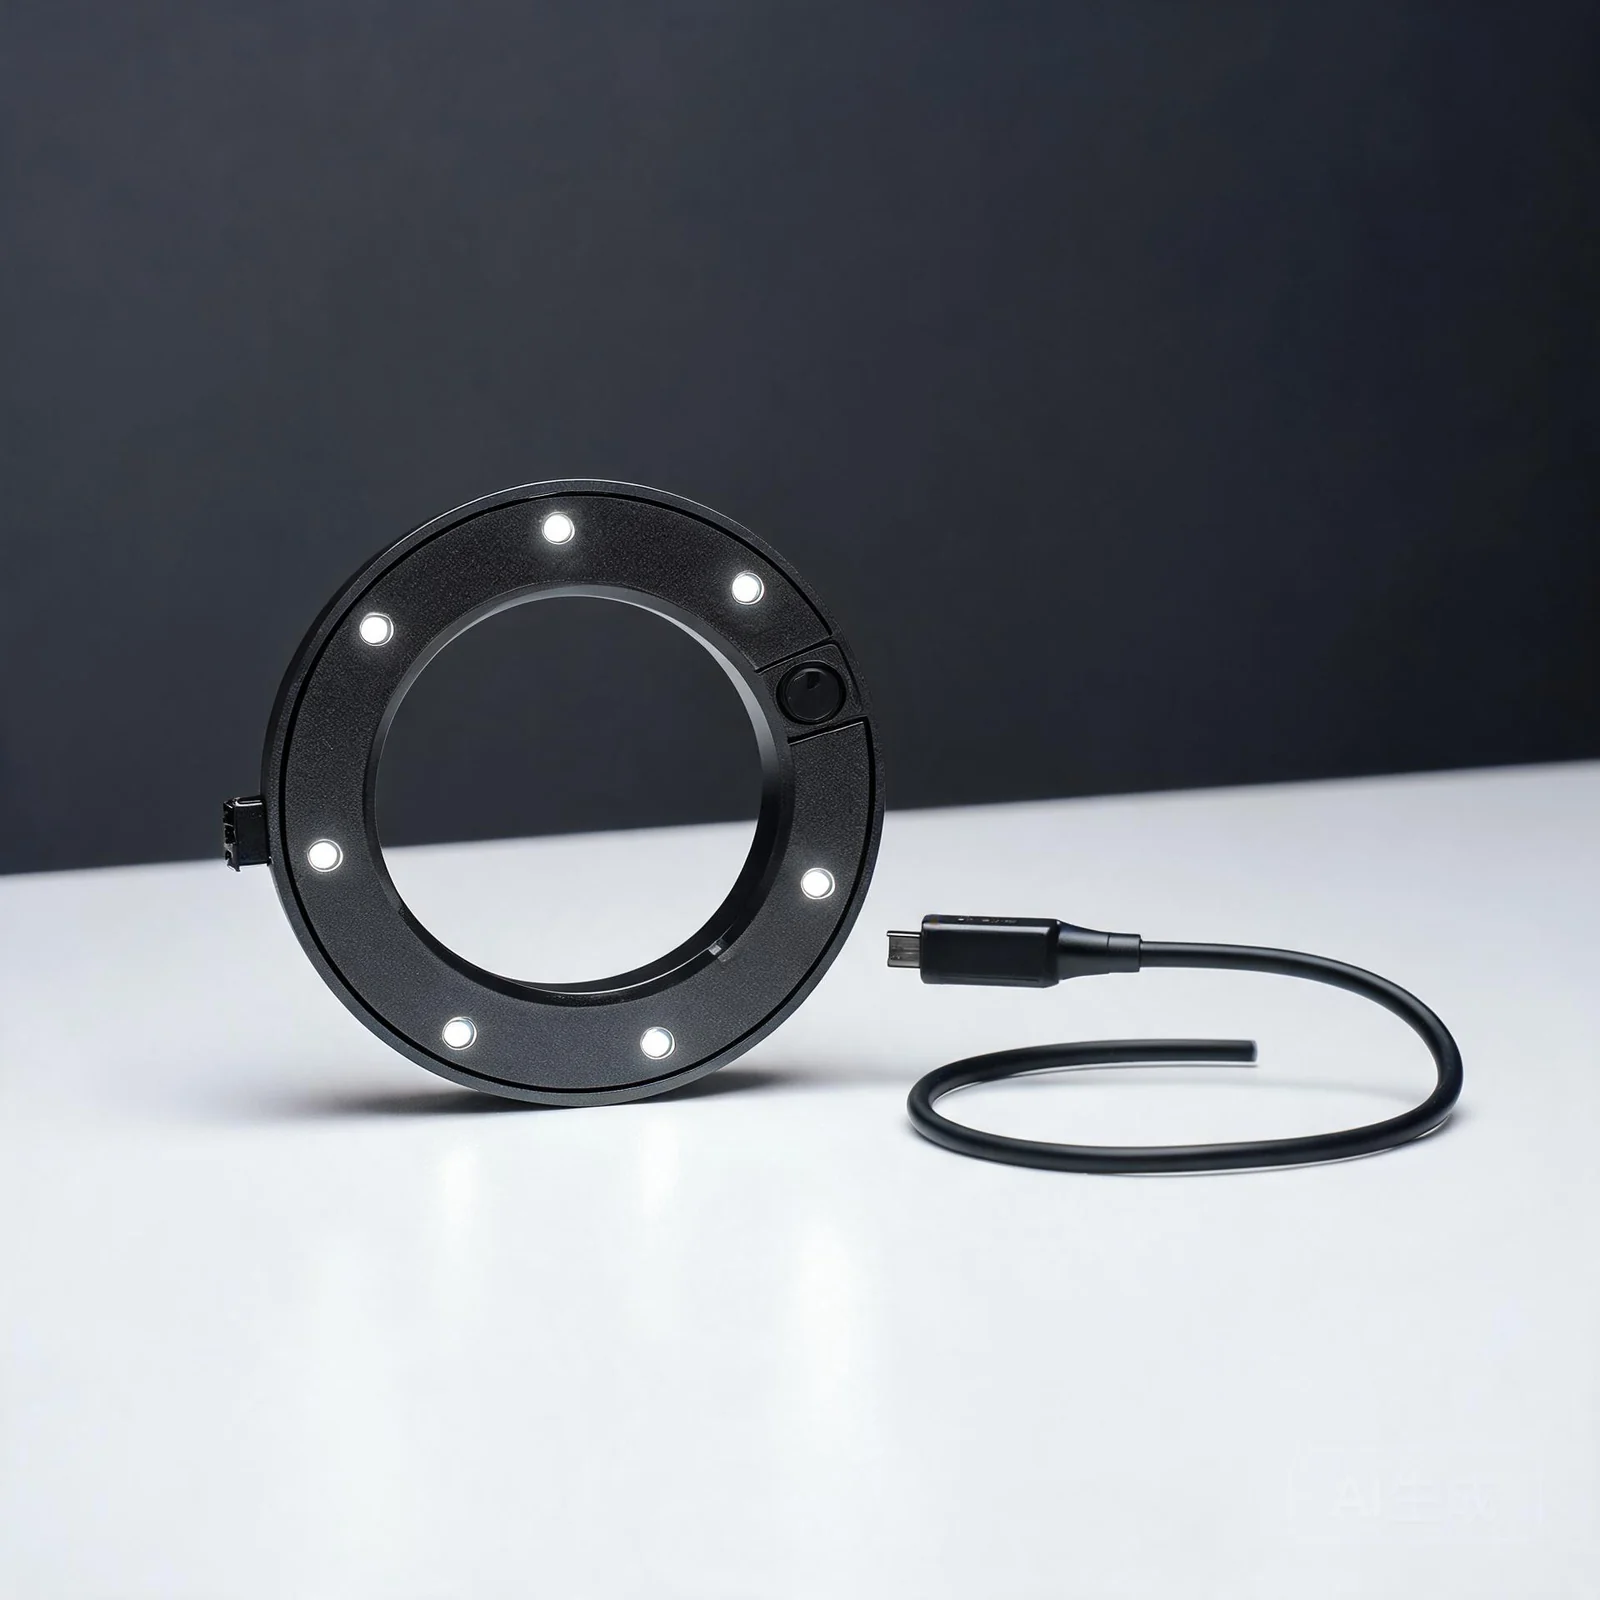
Development stage / supply to confirmRing Locator Module

Ring Locator Module

For locating grippers and external sensors; joint positioning and synchronization with E6/E8 are confirmed per project.

80glocator
Type-Cinterface
PPS + UARTsync interface
To be confirmedsupply to confirm
Peripheral sync
View details →
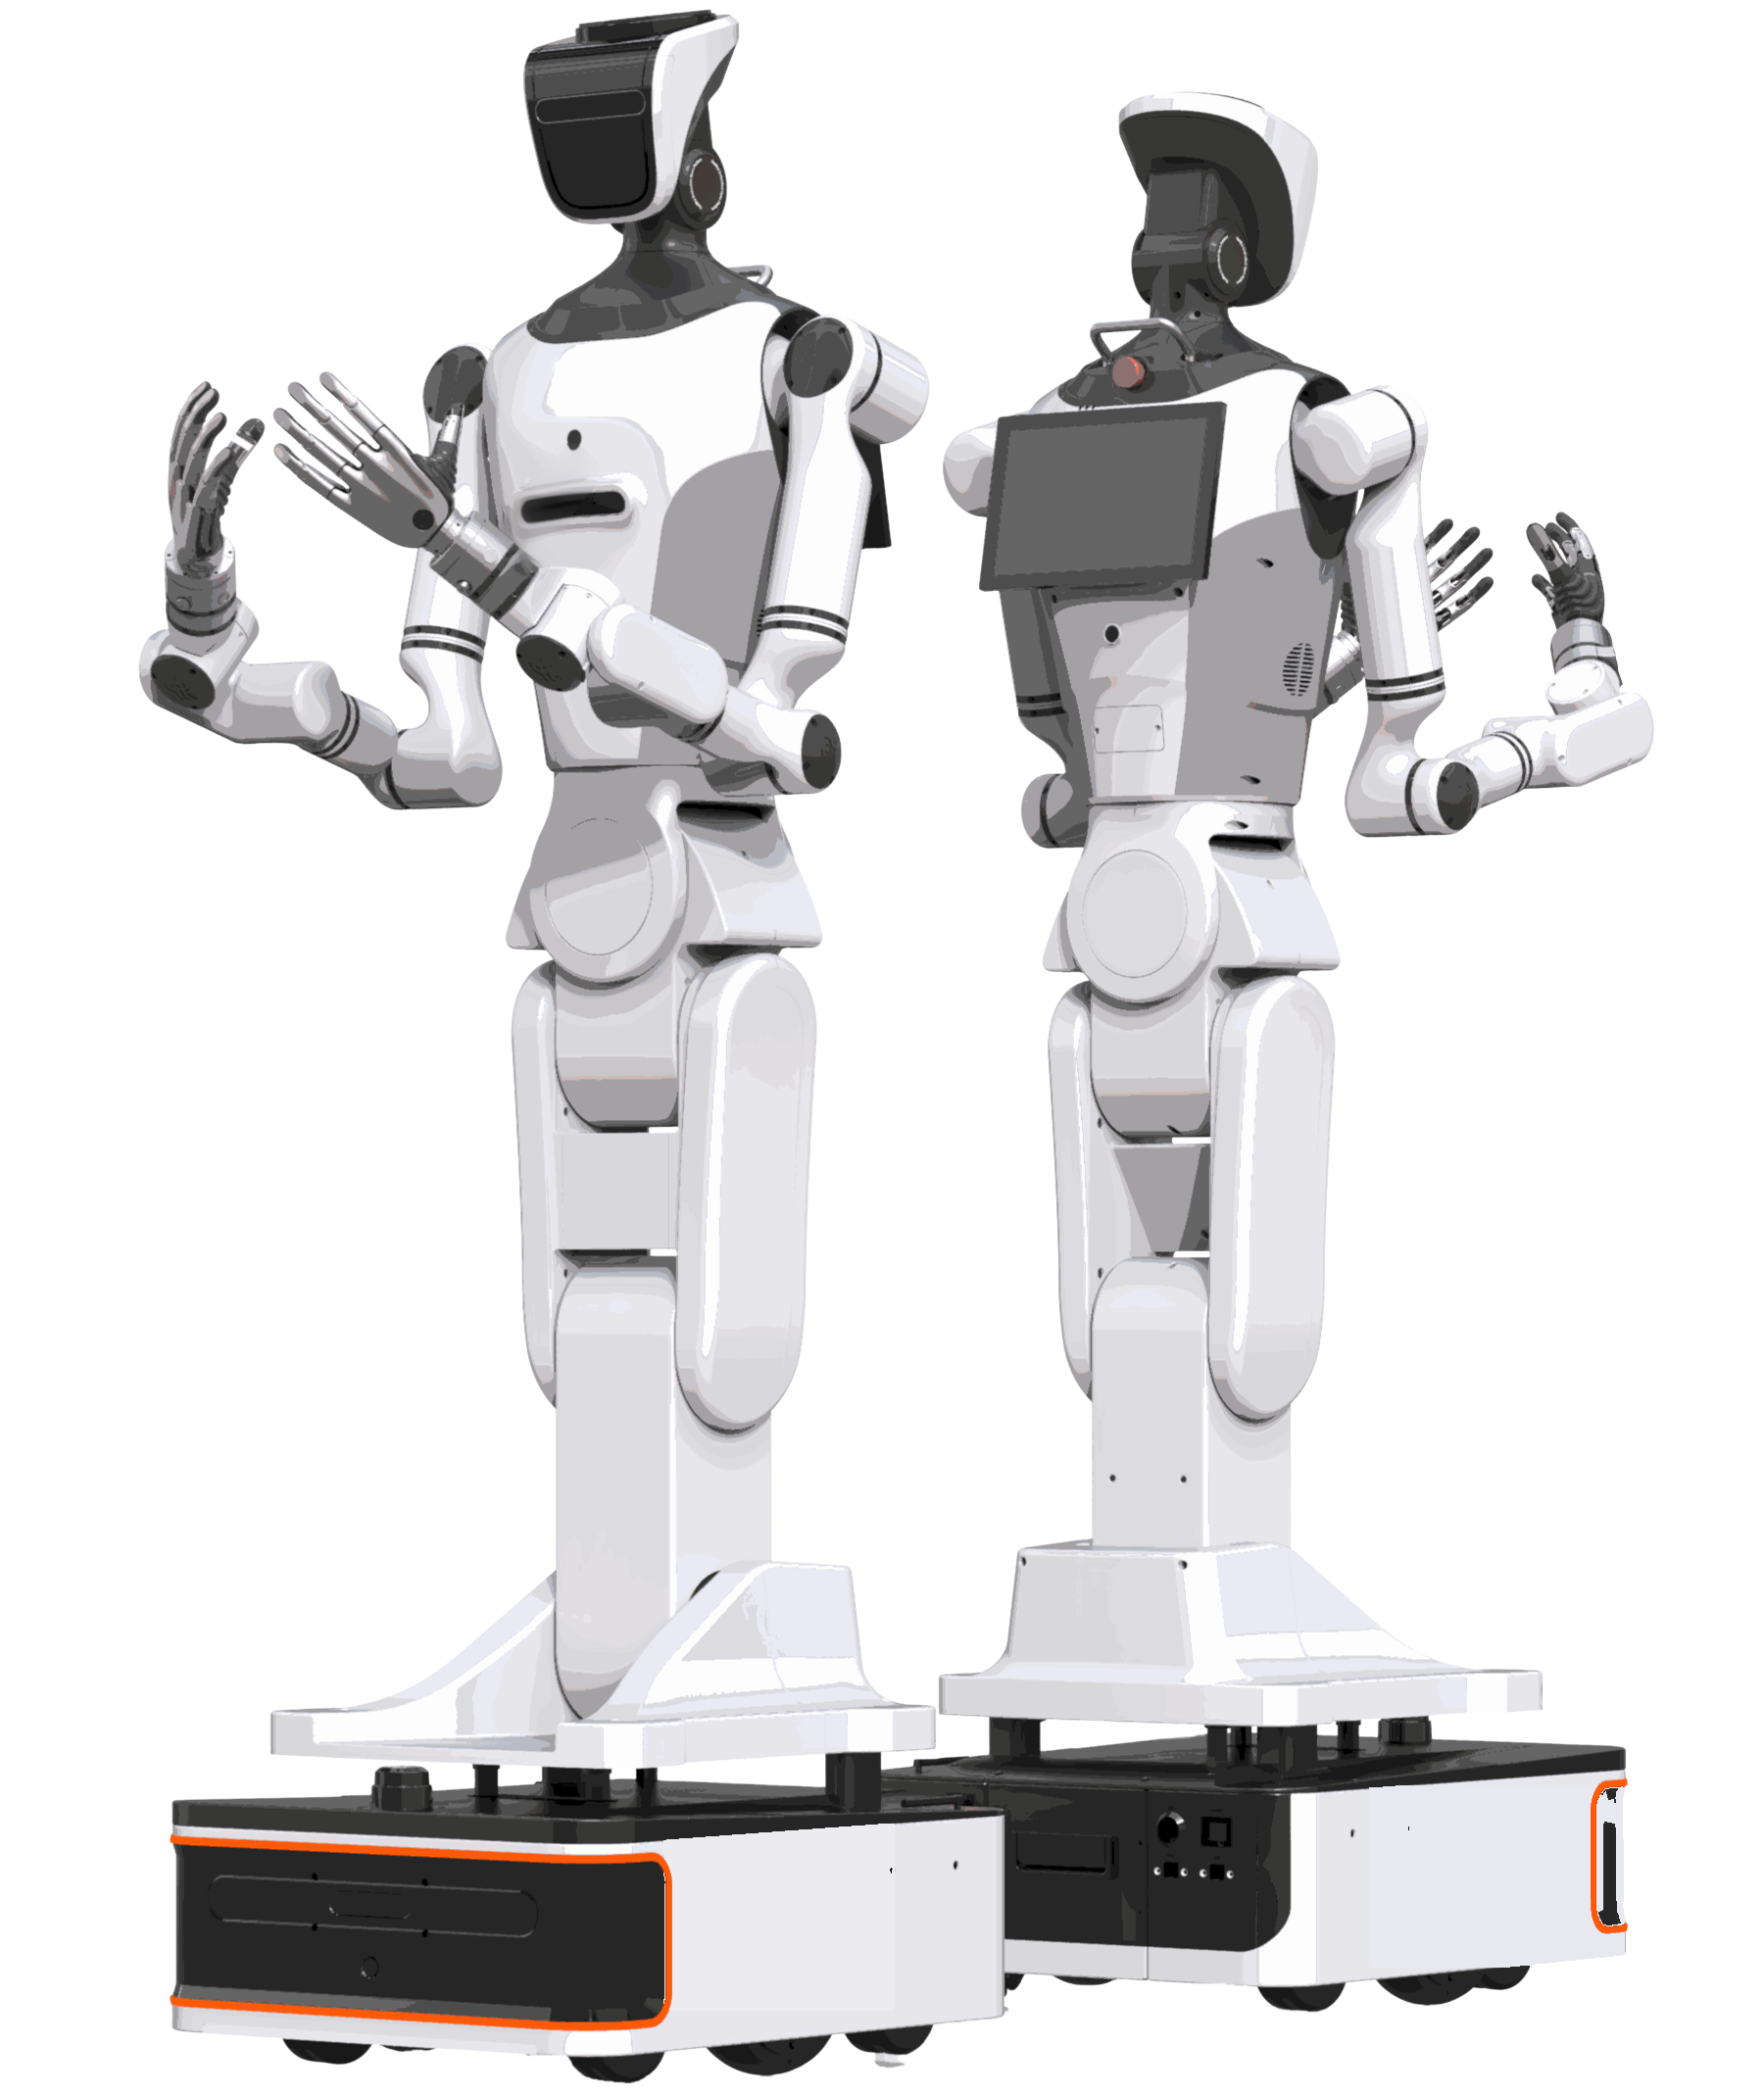
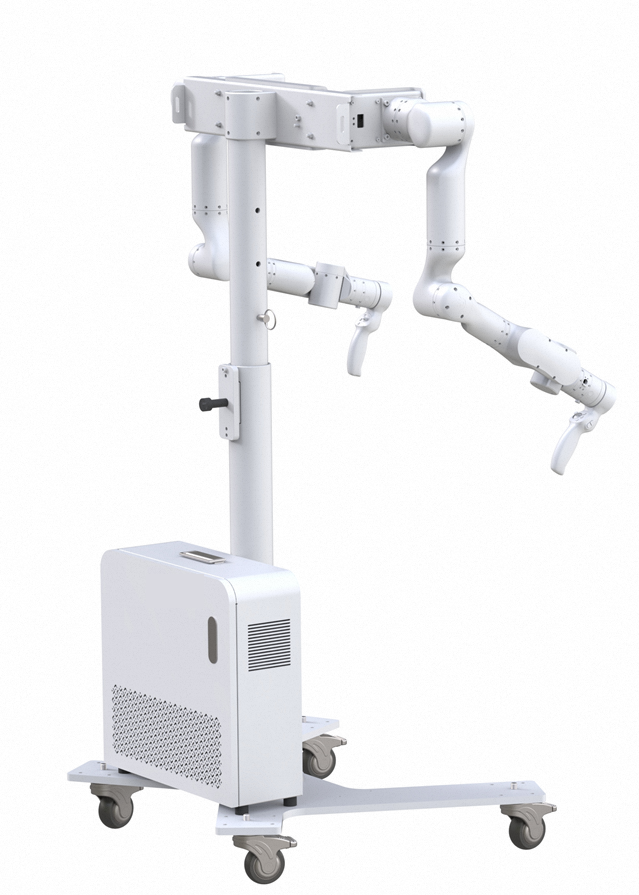
In productionFolding wheeled dual-arm teleop base

Folding wheeled dual-arm teleop base

20 DoF, 5 kg per arm, 0–2.1 m vertical workspace, four-wheel steering and drive, 48V 20Ah, about 6 h. End effector interface: 2-finger gripper or 5-finger hand, quick-change.

20 DoFwhole body
5 kgper arm
0–2.1 mvertical workspace
~6 h48V 20Ah
Peripheral sync
View details →
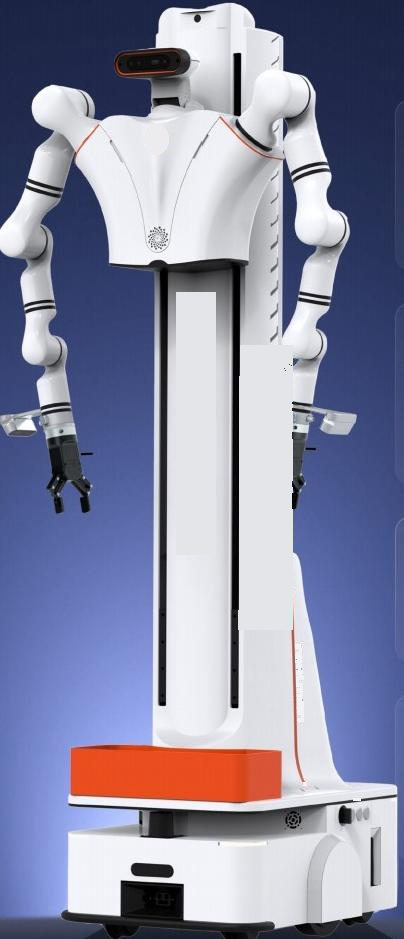
In productionLifting wheeled dual-arm teleop base

Lifting wheeled dual-arm teleop base

Model RMC-AIDAL. Folded 640×450×1780 mm, about 80 kg, 900 mm lift, 0–2.4 m vertical, 5 kg rated per arm, differential 1.5 m/s, LFP 48V 20Ah.

900 mmlift travel
0–2.4 mvertical
5 kgrated per arm
~80 kgmass
Peripheral sync
View details →
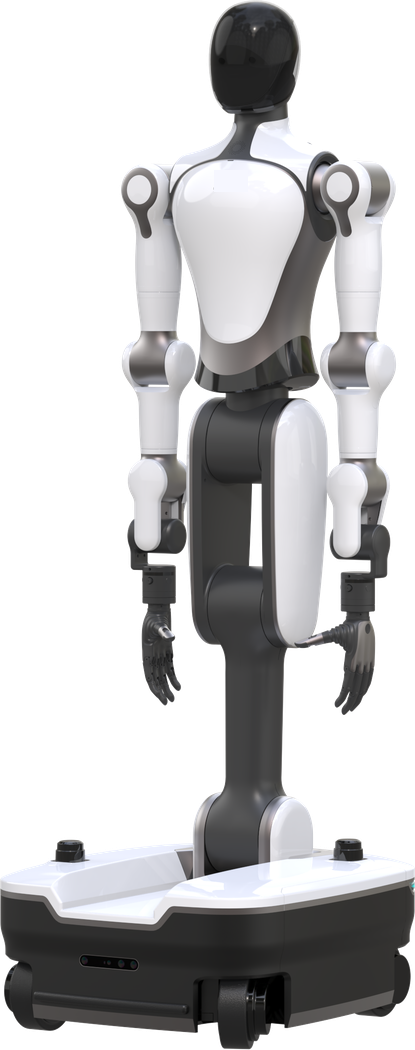
In productionWheeled humanoid teleop base

Wheeled humanoid teleop base

21 active DoF (arms 14, waist 3, legs 2, neck 2), 5 kg per arm, 570×465×1680 mm, 690 mm turning radius, 40 Ah battery, about 2 h charge.

21active DoF
5 kgper arm
690 mmturning radius
40 Ahbattery
Peripheral sync
View details →
In productionTeleoperation kit

Teleoperation kit

Three configurations: GLN-RX75 reach 709 mm, 7.8 kg, force feedback; GLN-RX71 reach 474 mm, 3.8 kg, force feedback; local isomorphic kit reach 599 mm, about 1.5 kg, no force feedback.

709 mmGLN-RX75
474 mmGLN-RX71
599 mmlocal kit
7 DoFall three
View details →
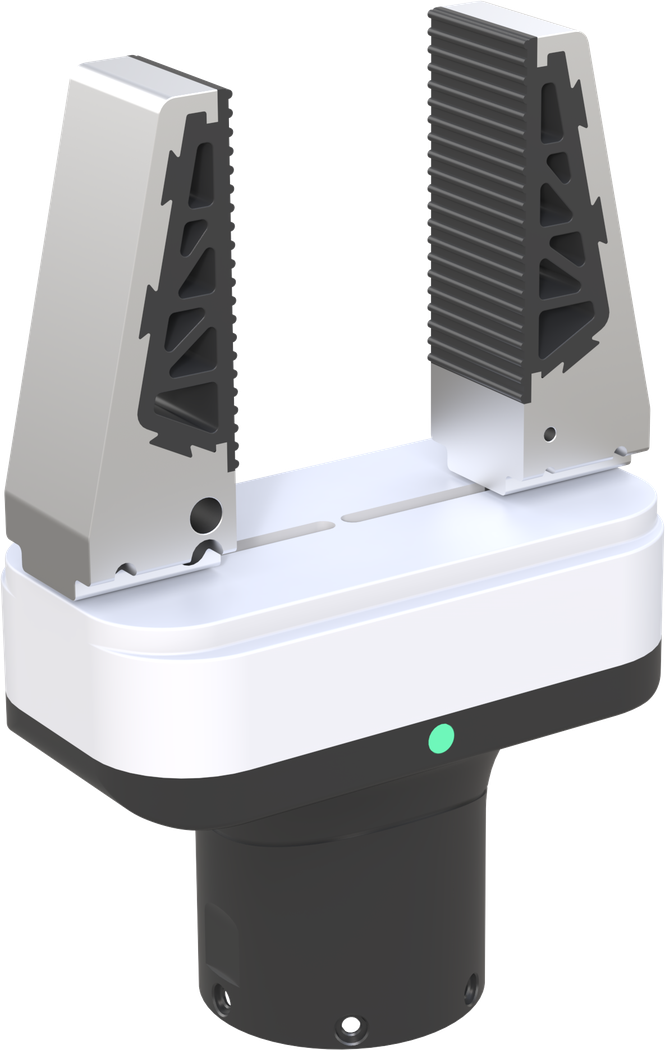
In productionParallel two-finger gripper RMG22-65

Parallel two-finger gripper RMG22-65

65 mm stroke, 130 N max grip force, 745 g. Max enveloping payload 5 kg; recommended max friction payload 2 kg. RS485 / Modbus-RTU.

65 mmstroke
130 Nmax force
5 kg / 2 kgenveloping / friction payload
745 gmass
View details →
Technical comparison
Select 1–3 devices to generate a comparison matrix

Need a capture-and-label plan?

If the model is not locked, we can review device, pilot capture, labeling, and versioned delivery together. You can also buy hardware only. Specs follow the latest written confirmation. English product summaries are available; full written specs remain on the Chinese detail pages.